Projects
Research
Ongoing graduate research in dynamics modeling and whole-body control, advised by Prof. Shinsuk Park.
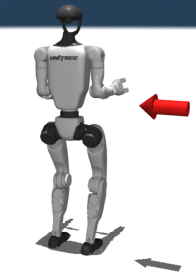
Measures how fast and accurate a sensorless humanoid's push estimate needs to be to safely hold in place instead of stepping — then uses that to cut base displacement by 96% on real pushes.
Role: First Author
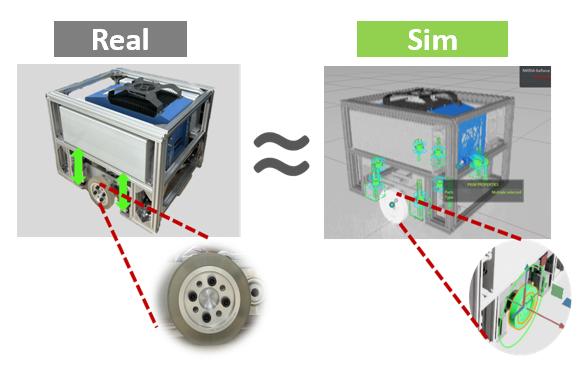
Tunes a simulator's wheel-friction and suspension parameters to real robot response data, cutting the sim-to-real trajectory gap of a LiDAR mapless-navigation RL policy by double digits — cross-validated with two independent trajectory-estimation methods.
Role: Co-author
Master's Research Encouragement Grant, National Research Foundation of Korea (2025)
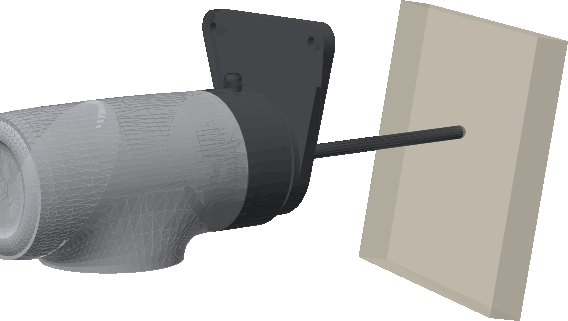
A control framework where the task specifies what to preserve under unknown contact — on tilted boards, it kept a drawn figure within 0.5 mm versus 10–18 mm for the standard nearest-point rule.
Role: First Author
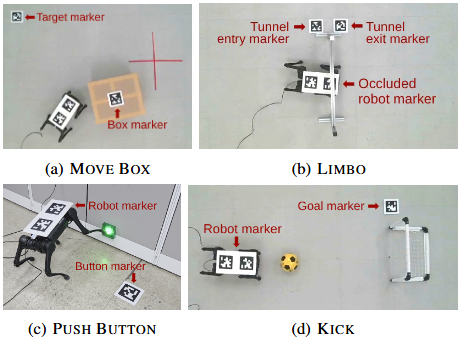
Adapts CALM's latent motion representations to quadruped control for transition-stable locomotion and object interaction.
Role: Co-author
A ROS2 architecture connecting simulation, an LLM, a UI, and a physical mobile manipulator, with edge-based data collection and automatic cloud sync that preserves the robot's real-time control cycle.
Role: System Architect
A physics-informed Balance Demand Descriptor, derived from centroidal dynamics, that lets a humanoid's control policy explicitly distinguish disturbances it can absorb in place from those requiring a corrective step.
Role: First Author
Earlier Projects
Undergraduate coursework and competition projects in mechanism design and robot perception.
President's Award (1st Place), Creative Challenger Program (CCP), Korea University — Jan.2025
Monocular ORB-SLAM depth estimation and UV-disparity segmentation for real-time obstacle avoidance on a quadruped, without a dedicated depth sensor.
Role: Team Leader, RoboStride
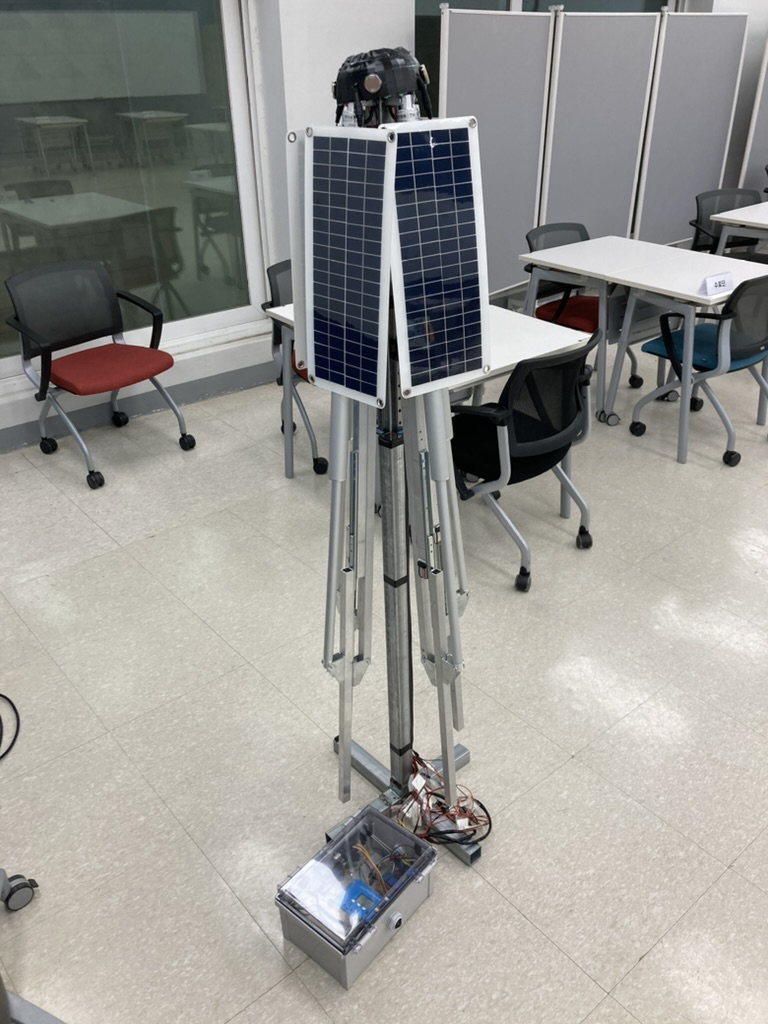
Bronze Award, Creative Comprehensive Design Competition — Sep.2023; Design Award, Capstone Design Fair, Korea University — Nov.2023
A parasol that senses sun position and actuates its canopy to track the sun and maximize shade throughout the day.
Role: Team Leader
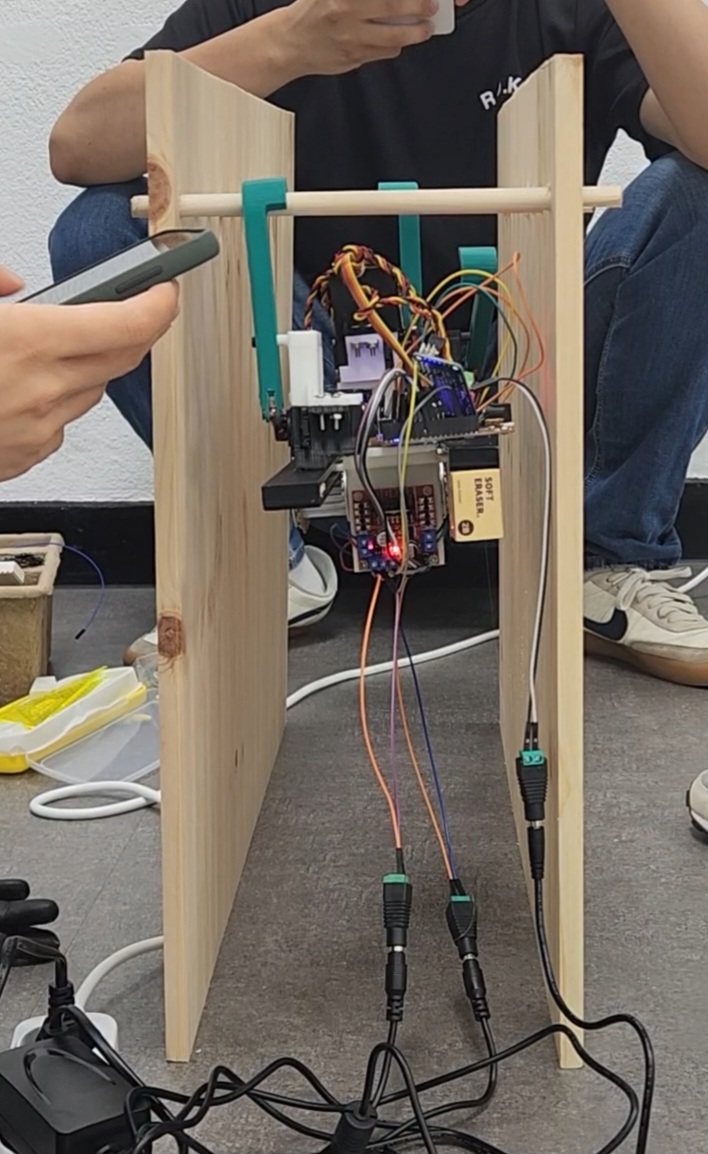
A tendon-driven, 3D-printed robot that climbs a horizontal ladder by gripping rungs and shifting its center of mass.
Role: Team Leader